Recently, supported by the National Key R&D Program, the project Intelligent Self‑Propelled Operation and Maintenance Equipment for Rail Transit Traction Power Catenary — jointly developed by China Railway Electrification Engineering Group Co., Ltd. and other partners — has achieved major progress. Its core achievement has completed demonstration application on the Guangzhou-Zhanjiang High-Speed Railway.
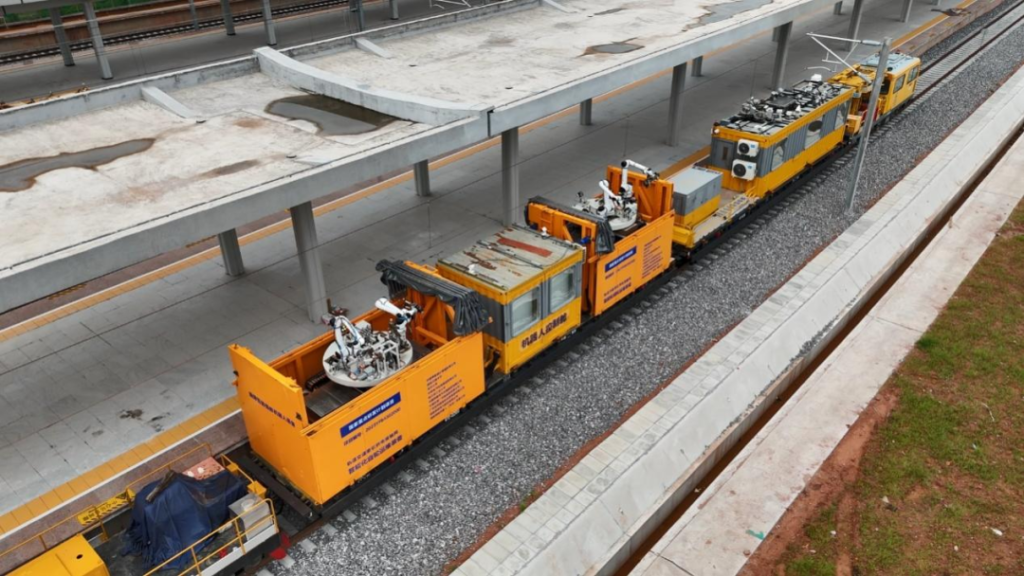
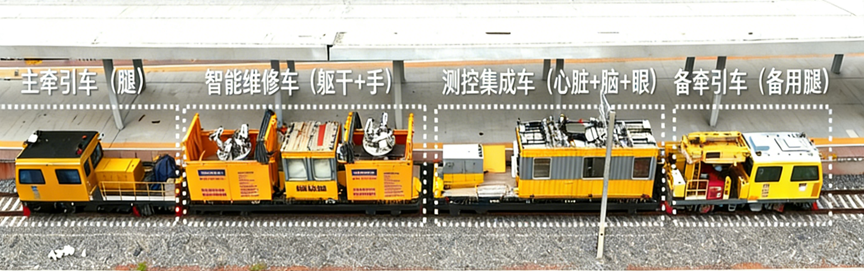
This vehicle system is an intelligent catenary O&M platform integrating autonomous perception and positioning, catenary automatic inspection, cloud-edge evaluation, and on-board robot maintenance. It supports full‑process autonomous operation under complex conditions and replaces more than 80% of daily manual work, marking a strategic leap from traditional “inspection vehicle + manual maintenance” to intelligent perception, autonomous operation and systematic O&M.
Leveraging proprietary perception and train control technologies, FITSCO led the key sub-task: Research on Accurate Positioning and Automatic Alignment Methods for Vehicle Groups, delivering the “Intelligent Eye & Precision Foot” system for the equipment.
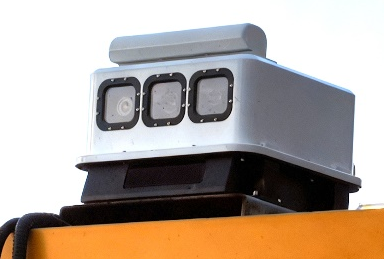
- Intelligent Eye: Multi‑sensor fusion enables full‑time, full‑scene high‑precision positioning, locating catenary faults at centimeter level.
- Precision Foot: On-board automatic driving system controls the vehicle group to automatically travel and precisely stop at maintenance points with decimeter‑level accuracy, laying the foundation for robotic autonomous maintenance.
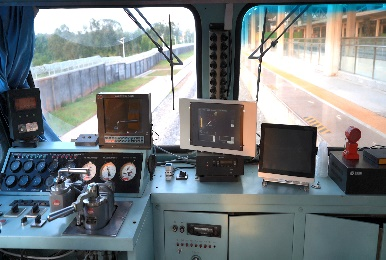
Key technological breakthroughs:
- autonomous precise positioning: relying on on-board multi-sensor and contact network basic data, accurate positioning is achieved through feature matching, no equipment on the ground is required, and deployment is more flexible.
- Multi-dimensional algorithm fusion positioning: fusion real-time mapping, wheel axis odometer and other multiple algorithms, to achieve multi-source
- Full-time and full-scene adaptive positioning: stable positioning under all- weather and all-working conditions, regardless of environmental and operating conditions.
- Traction braking model self-learning: The parameters of the traction braking control model of the vehicle group are autonomously iterated, adaptive to complex working conditions, and more accurate dynamic control.
- Multi-level collaborative precise positioning: multi-level control algorithm is adopted to realize automatic and precise docking, stable positioning and one-time positioning.
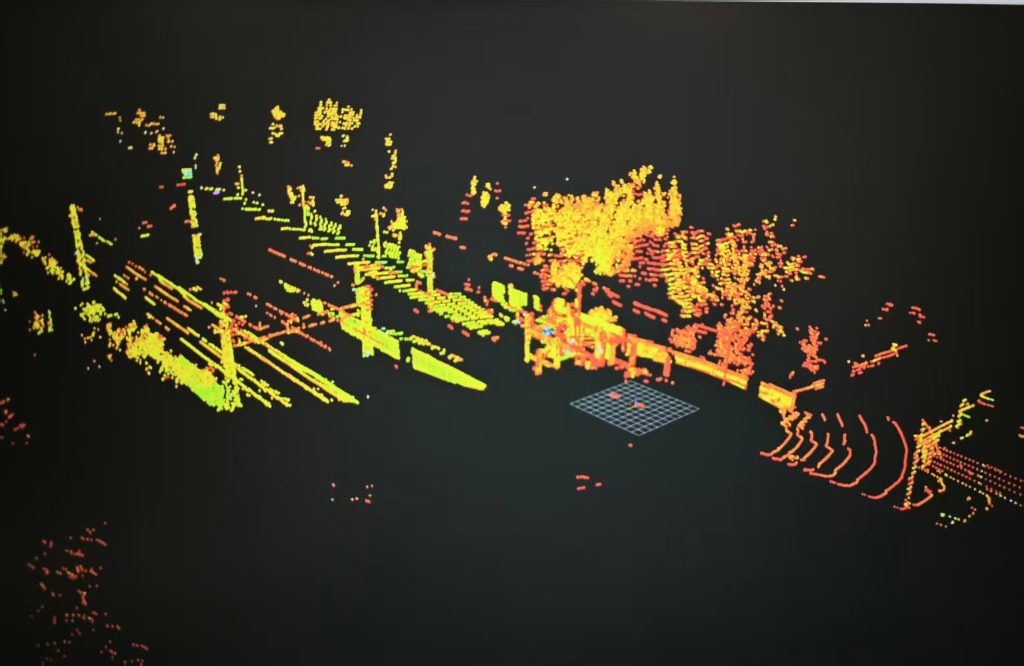
This equipment has been selected as a core exhibit by the State‑owned Assets Supervision and Administration Commission (SASAC) in the field of physical intelligence and high‑risk welding, demonstrating China’s global leadership in high‑end equipment and AI integration.
FITSCO’s precision positioning and automatic alignment technology can be widely applied to high‑speed rail and urban rail transit. It provides flexible, reliable solutions for the intelligent upgrading of self‑propelled maintenance vehicles and supports the large‑scale application of artificial intelligence in rail transit.